MS Office 365 is the web-based version of MS Office (Word,Excel, etc). Its functionality is limited comparing to the original desktop version, it feels like MS Works I used 1992. But the worst, it is not possible to copy&paste between two documents in two different web-browser windows, no clipboard! A limited clipboard is available via browser-plugin only, but it did not work with Firefox on Ubuntu 2022.
Author Archives: frehberg
Buildroot Verity Setup – Rootfs Integrity
I investigated the usage of Verity feature of Linux kernel, ingrating this feature into the OpenCritis environment. The Verity Device Mapper of the Linux kernel is verifying the integrity of a read-only file system (eg partition rootfs) using a Merkle tree; over the data blocks of the file system. If signing the top hash, the authenticity and integrity of the rootfs can be enforced while booting and during runtime!
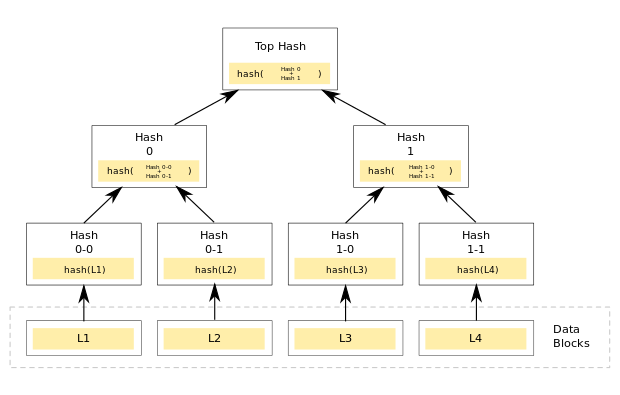
Credits: Nathan Barrett-Morrison did a very good posting explaining the details https://www.timesys.com/security/dm-verity-without-an-initramfs/
Locking down U-Boot Environment
Performing secure boot U-Boot, the U-Boot-Env in mmc or flash should be static, read-only. In case of A-B boot concept as being used for OpenCritis, the bootloader needs to know the active partition to boot into. Therefore 3 variables shall be writable only, being stored in U-Boot Environmentn, namely
boot_order: Hex value, either “AB” or “BA”
boot_a_left: Dec value counting the number of trials, by default 3
boot_b_left: Dec value counting the number of trials, by default 3
To acieve this setup the uboot defconfig should have the following setup:
CONFIG_CMD_ENV_CALLBACK=y
CONFIG_CMD_ENV_FLAGS=y
CONFIG_ENV_IS_NOWHERE=y
CONFIG_ENV_IS_IN_MMC=y or CONFIG_ENV_IS_IN_FAT=y
CONFIG_ENV_APPEND=y
CONFIG_ENV_WRITEABLE_LIST=y
CONFIG_ENV_ACCESS_IGNORE_FORCE=y
CONFIG_CMD_NVEDIT_LOAD=y
CONFIG_SYS_CONSOLE_ENV_OVERWRITE=y
In the board header file (eg. include/configs/qemu-arm.h) the following definitions must be added , for example as patch file.
#define CONFIG_ENV_FLAGS_LIST_DEFAULT "boot_order:xw,boot_a_left:dw,boot_b_left:dw"
#define CONFIG_ENV_FLAGS_LIST_STATIC  "boot_order:xw,boot_a_left:dw,boot_b_left:dw"
See the following README explaining the flag attributes: https://github.com/u-boot/u-boot/blob/master/README#L1588
Program your Presentation with reveal.js
if you are developer and PowerPoint, Google Slides etc. are too much “Klicki bunti”, the framework reveal might be the ideal alternative for you.
Solar Position Algorithm (SPA) release 0.3.0
The release 0.3.0 of the crate spa is fixing the flaw of the API, and updating to Rust edition 2021.
The SPA can be used to calculate solar position (azimuth and zenith_angle) and the time of sunrise and sunset. This data can be used to optimize the position of solar panels, to optimize load-cycles of energy storages, or to increase or reduce the lighting at home or in vehicles.
As for the flaw in the API: Just implementing unittests, I wasn’t aware that the members of the structure SolarPos lacked the declaration pub. Users of the lib were not able to read the result from return value! Now, after adding example files, these examples are verifying those members are publicly accessible, see below.
// ...
pub enum SunriseAndSet {
    PolarNight,
    PolarDay,
    Daylight(DateTime<Utc>, DateTime<Utc>),
}

// ...
pub struct SolarPos {
    // horizontal angle measured clockwise ...
    pub azimuth: f64,
    // the angle between the zenith and the center of the sun's disc
    pub zenith_angle: f64,
}
Moreover the bench tests caused additional complexity due to the required feature handling and conditional builds. For that reason the bench tests have been removed.
In the moment the bench API is getting stabilized any time in future, these bench test will be put back.
Lessons learned: Avoid superfluous complexity and ship with examples always!
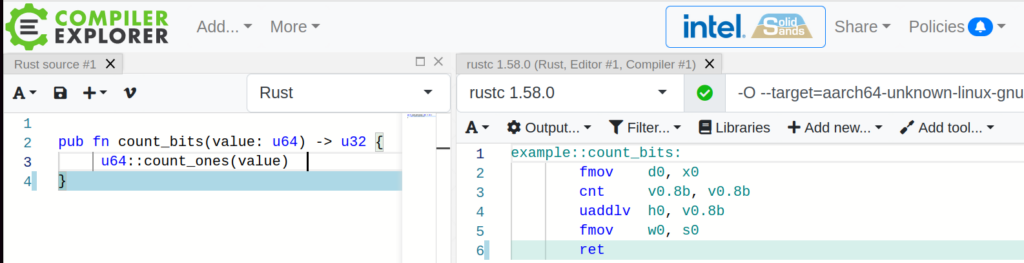
Compiler Explorer targeting ARM
I prefer ARM assembly. Adding the following Rust compiler option “–target=aarch64-unknown-linux-gnu”, the output of the Compiler Explorer will be ARM assembly
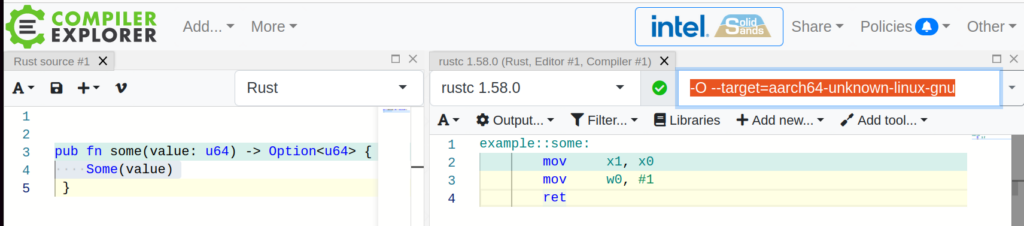
Another example, analyzing the generated code on ARM64 performing a bit-count, using the instruction CNT from vector unit.